General-purpose control model
LeMotion
Explore whole-body motion, motion authoring and teleoperation — the starting point for cerebellum development.
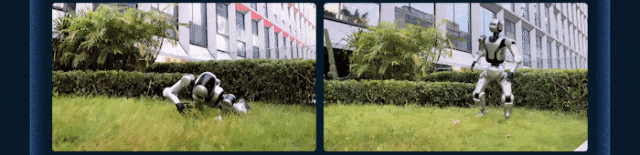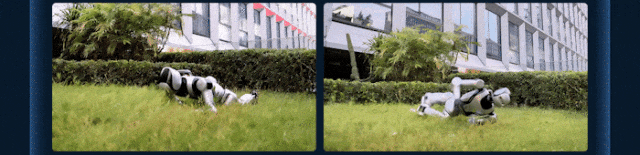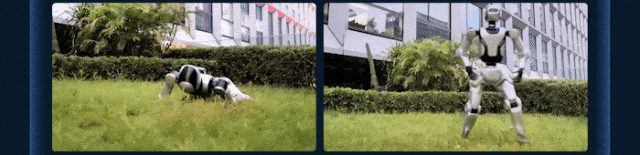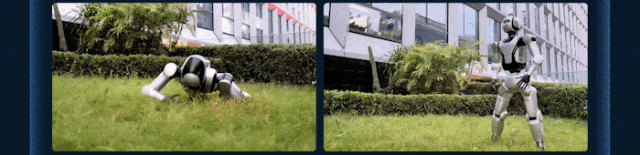
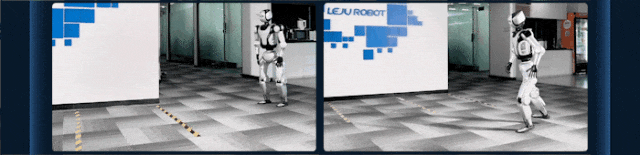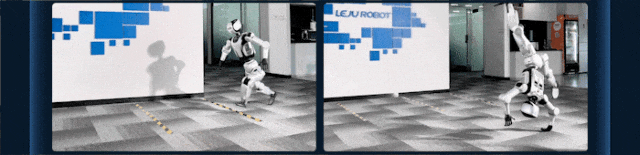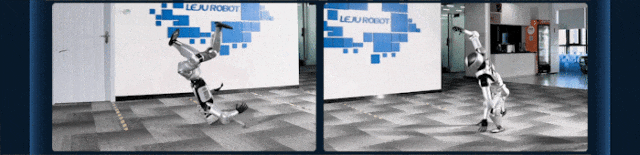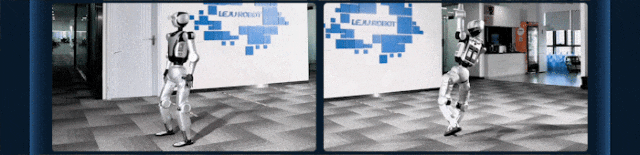

Browse project sites and open-source code for cerebellum motion control and brain manipulation, then follow a development path into motion, manipulation and skills.
Motion retargeting, reinforcement learning and whole-body deployment
Explore whole-body motion, motion authoring and teleoperation — the starting point for cerebellum development.
From motion retargeting and policy training to simulation and real-robot deployment, covering x86 and ARM platforms.
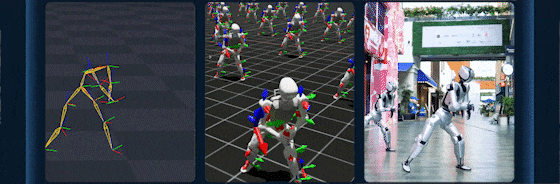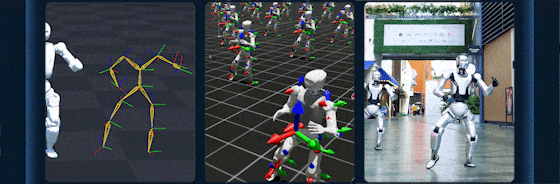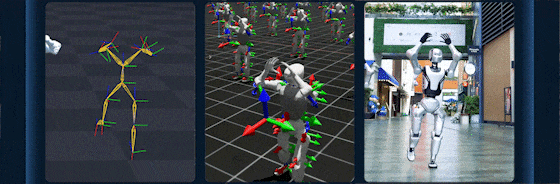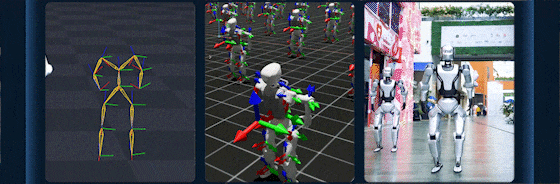
Manipulation models, training and real-robot deployment
Built for general industrial manipulation; post-train with demonstration data and the toolchain.
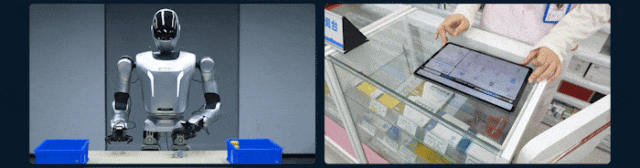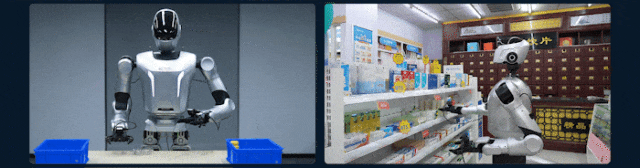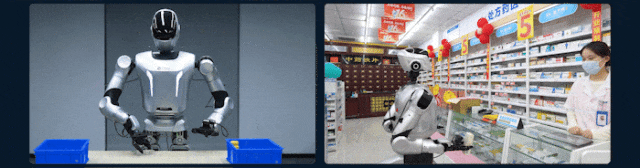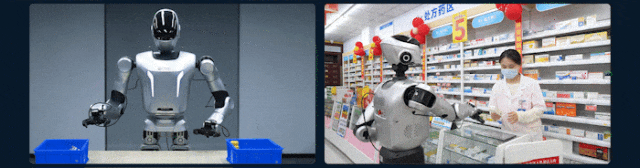
Connect data collection, processing, model training and real-robot deployment to complete manipulation tasks.
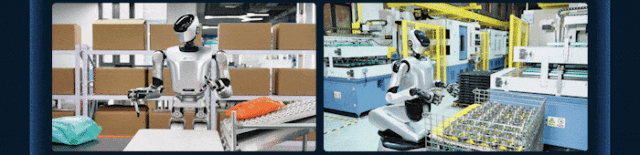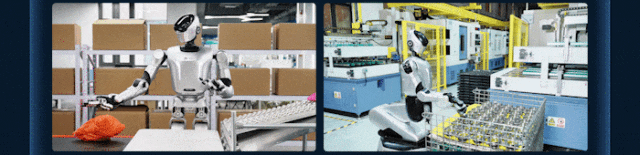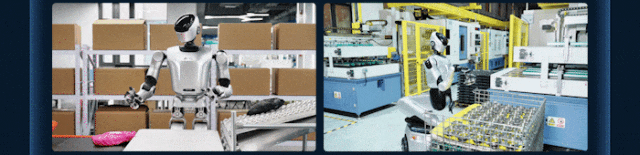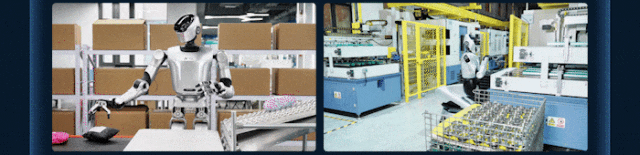
Reuse atomic skills, integrate manipulation models, and develop and validate new robot skills.
AI-assisted development, task orchestration and batch deployment
AI-driven case development
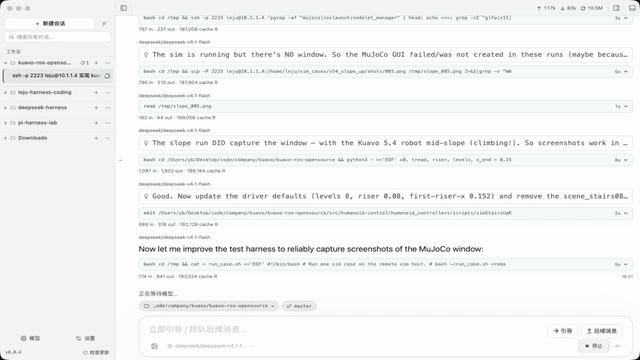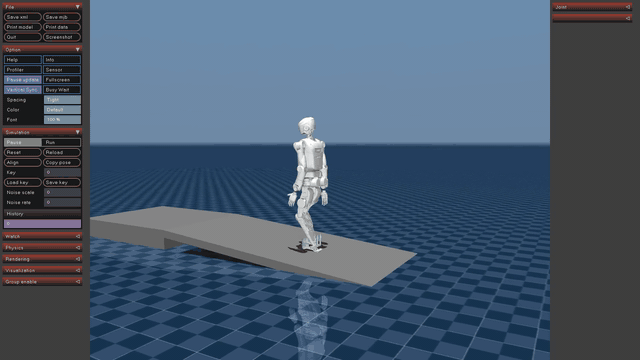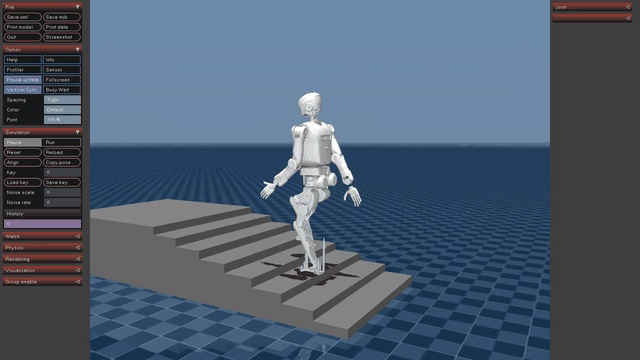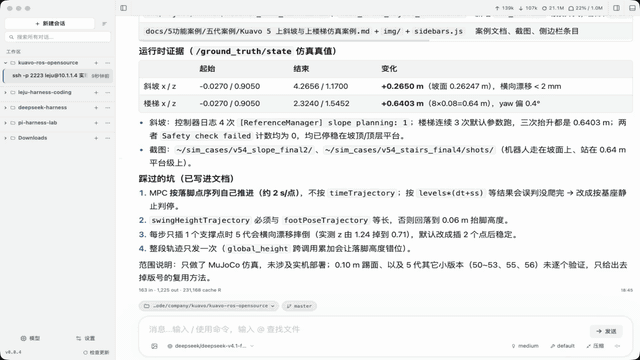
For task orchestration, batch deployment and operations management.
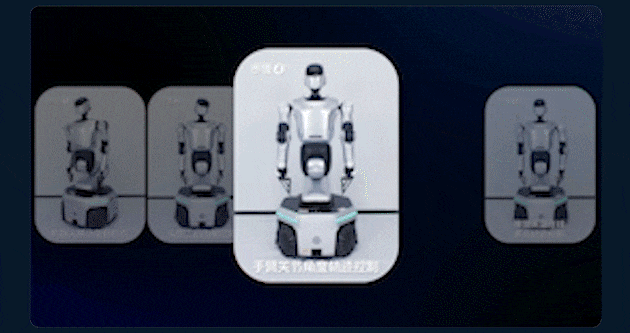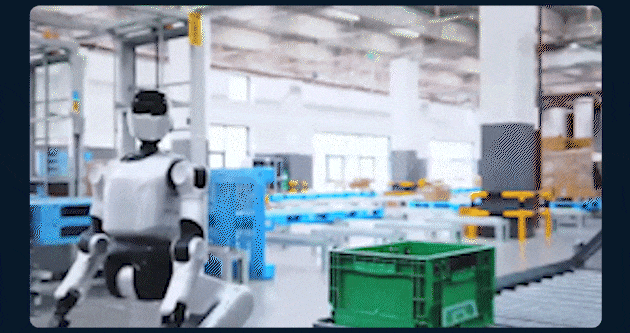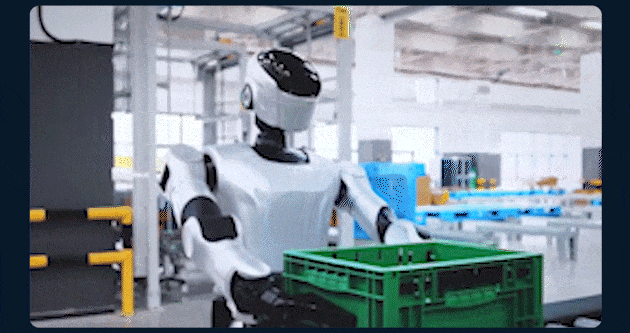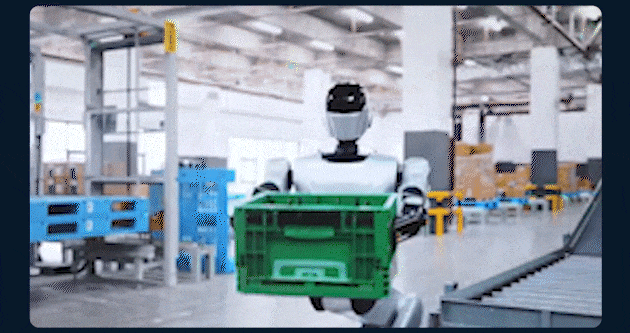
Move from data and foundation models to development tools, and build motion, manipulation skills and applications.
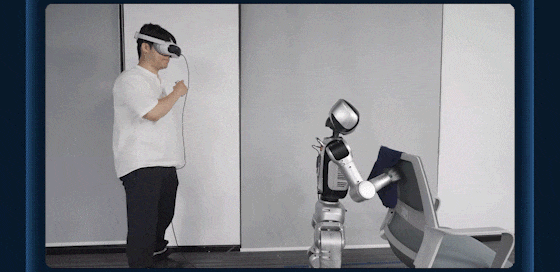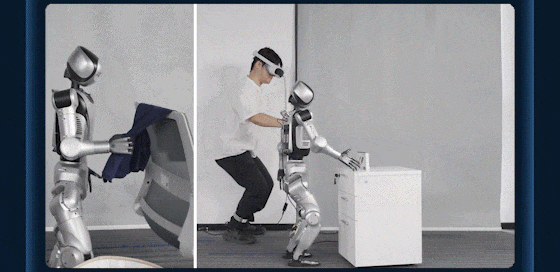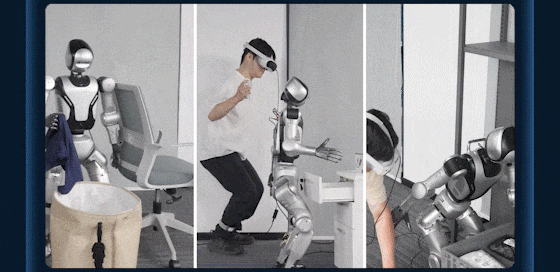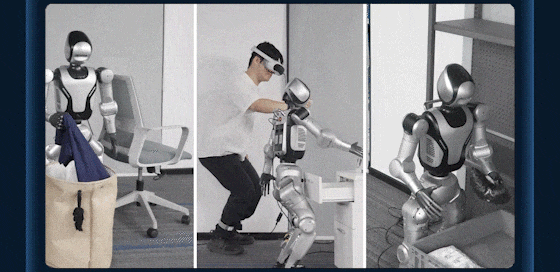
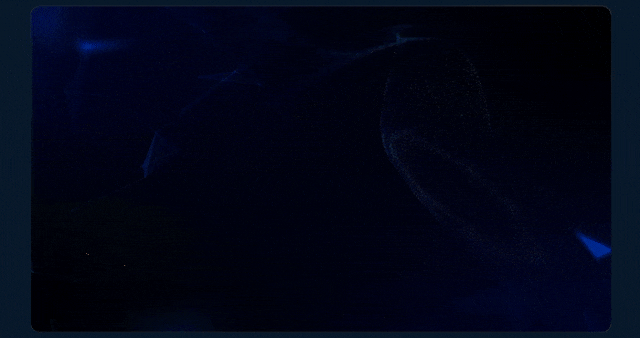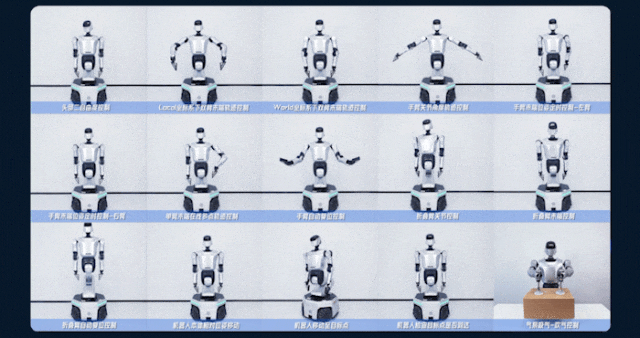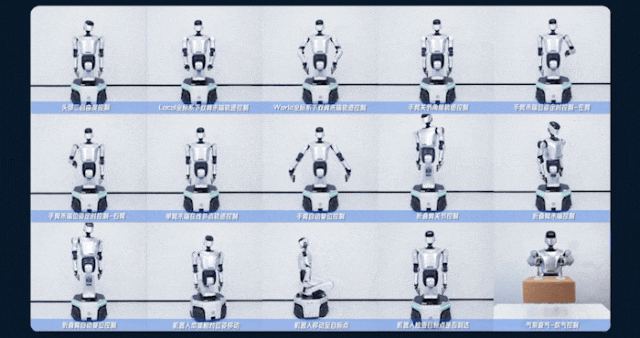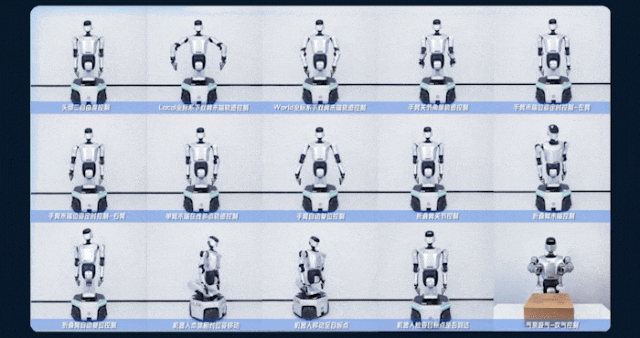
Real-robot teleoperation and task demonstrations
General industrial manipulation capability
Data collection, processing, training and real-robot deployment
Reuse skills, integrate models, develop new skills
Sorting, pick-and-place, machine tending
AI-driven case development
Coming soonEmbodied software platform: orchestration, deployment and management
Coming soonStart from a common development question and find the matching project and demo.
Import a video into the dance creation platform, tune parameters visually, then train and deploy to complete a motion.
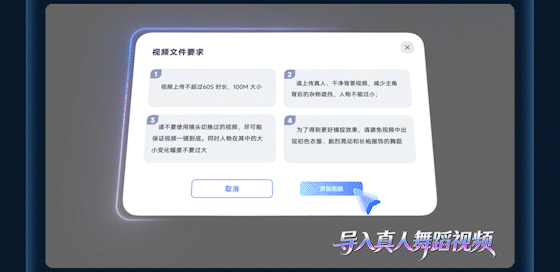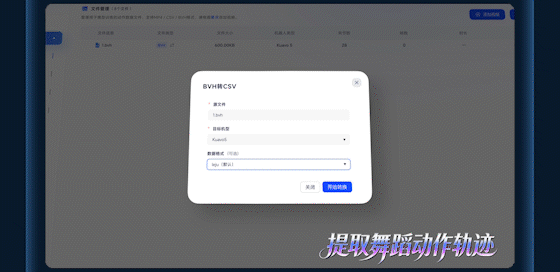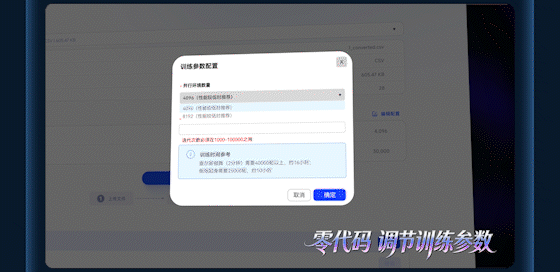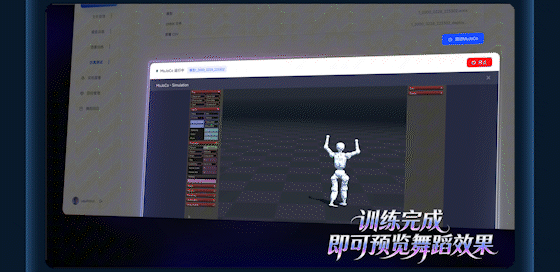
Pick motion data for your robot, then follow Leju-GMR → LejuLab-Train → LejuLab-Deploy for retargeting, simulation training and real-robot deployment.
Choose existing manipulation data or record task demonstrations, then train and deploy the model with LeTools-Learning.
The brain generates manipulation policies while the cerebellum executes whole-body motion. Combine the manipulation toolchain with LeMotion to build mobile pick-and-place and transfer tasks.